Introduction
Welcome to the Path Planning Subteam!
Purpose
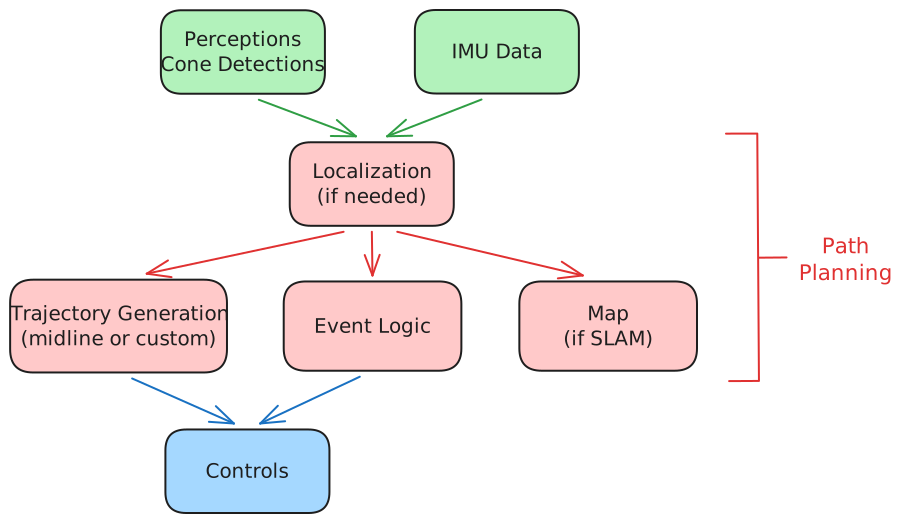
Section titled “Purpose”The Path Planning subteam is responsible for converting perceptions outputs into a drivable trajectory for the racecar. The planner receives environmental information (cones, vehicle pose, IMU data, etc.), determines where the vehicle should drive, and publishes a smooth path for the controls stack to follow. Different Formula SAE Driverless events have different requirements. While the overall objective remains producing a safe trajectory, each event requires a different planning strategy.
Responsibilities
Section titled “Responsibilities”Path Planning is responsible for:
- Receiving perceptions outputs
- Colored or uncolored cone detections
- IMU data
- Recoloring Cones if needed
- Constructing a drivable centerline or trajectory
- Localizing the vehicle and state estimation when required
- Detecting event completion
- Publishing trajectories to Controls
General Planning Pipeline
Section titled “General Planning Pipeline”